Scaling robot training data.
Partnership.
- Direct partnership
- You define tasks, objects and acceptance criteria. We set up stations, train operators and collect.
- Full data rights
- Each dataset is collected for one partner and transferred with full rights. We never resell or reuse it.
Operations
Bimanual end-effector states with access to industrial environment.
Delivering scale through two locations working in parallel: data collection and processing in Ahmedabad, India, and robotics software development and verification in California, USA.
Today
18
operators
up to1,000
hours a week
Dataset
Download 50 sample episodes for free.
Bimanual demonstrations recorded by Newlithic operators, published in LeRobot format on Hugging Face.
Get the samples on Hugging Face ↗
Access is gated. Sign in to Hugging Face and accept the dataset terms to download.
- Episodes50 bimanual demonstrations
- TaskUnscrew an M5 nut from a bolt held by the other hand
- Per handEnd-effector position in metres, rotation as the first two columns of the rotation matrix (6D), and gripper opening
- VideoWrist camera view
- Rate30 fps, video and state synced
- FormatLeRobot dataset (parquet + MP4)
- LicenseApache-2.0
Hardware
We can design, source or extend to any end effector or tool.
We can scale the end-effector joint space to a partner's requirement, or use the partner's hardware.
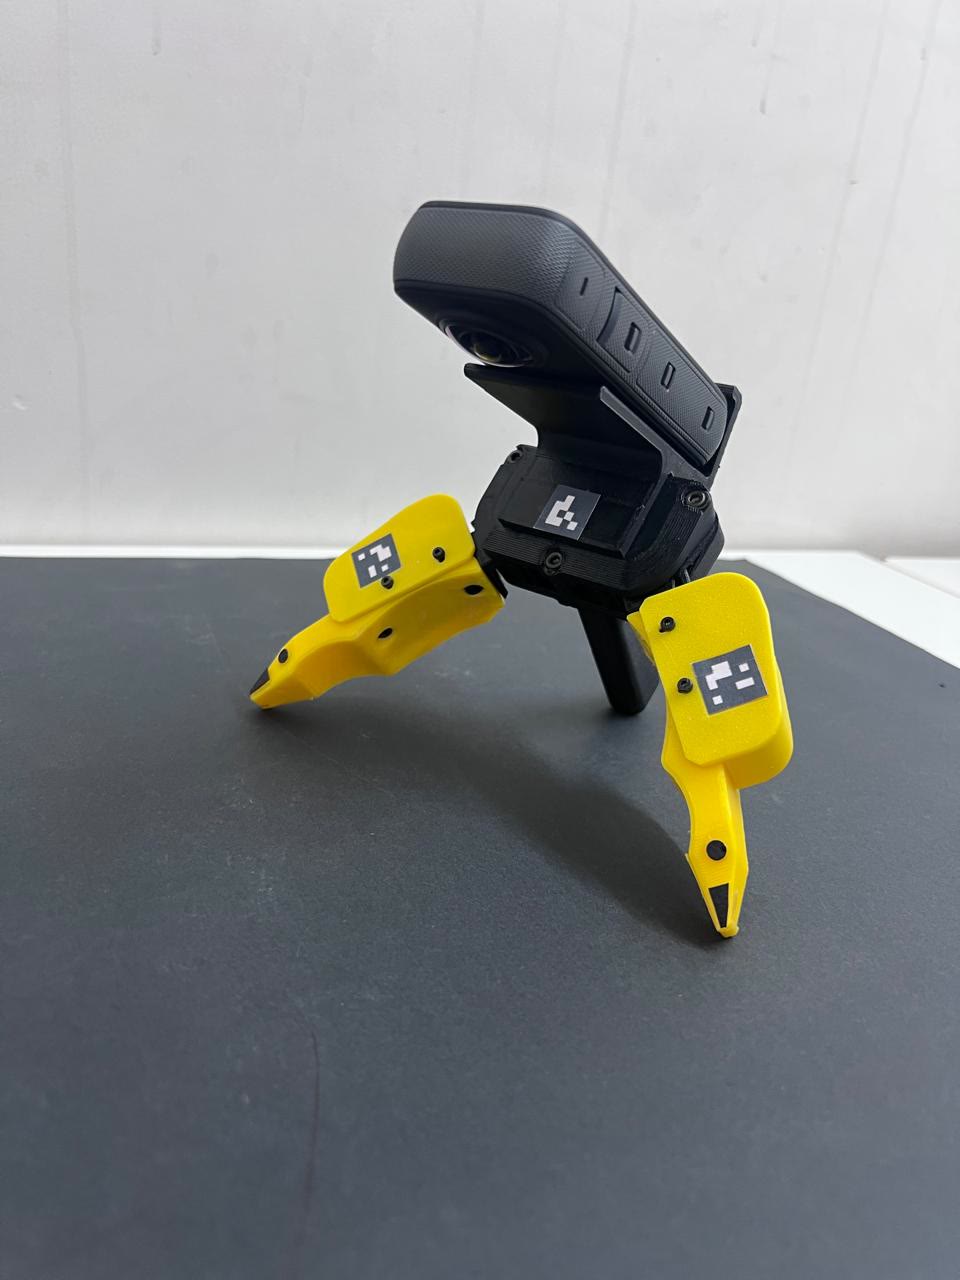
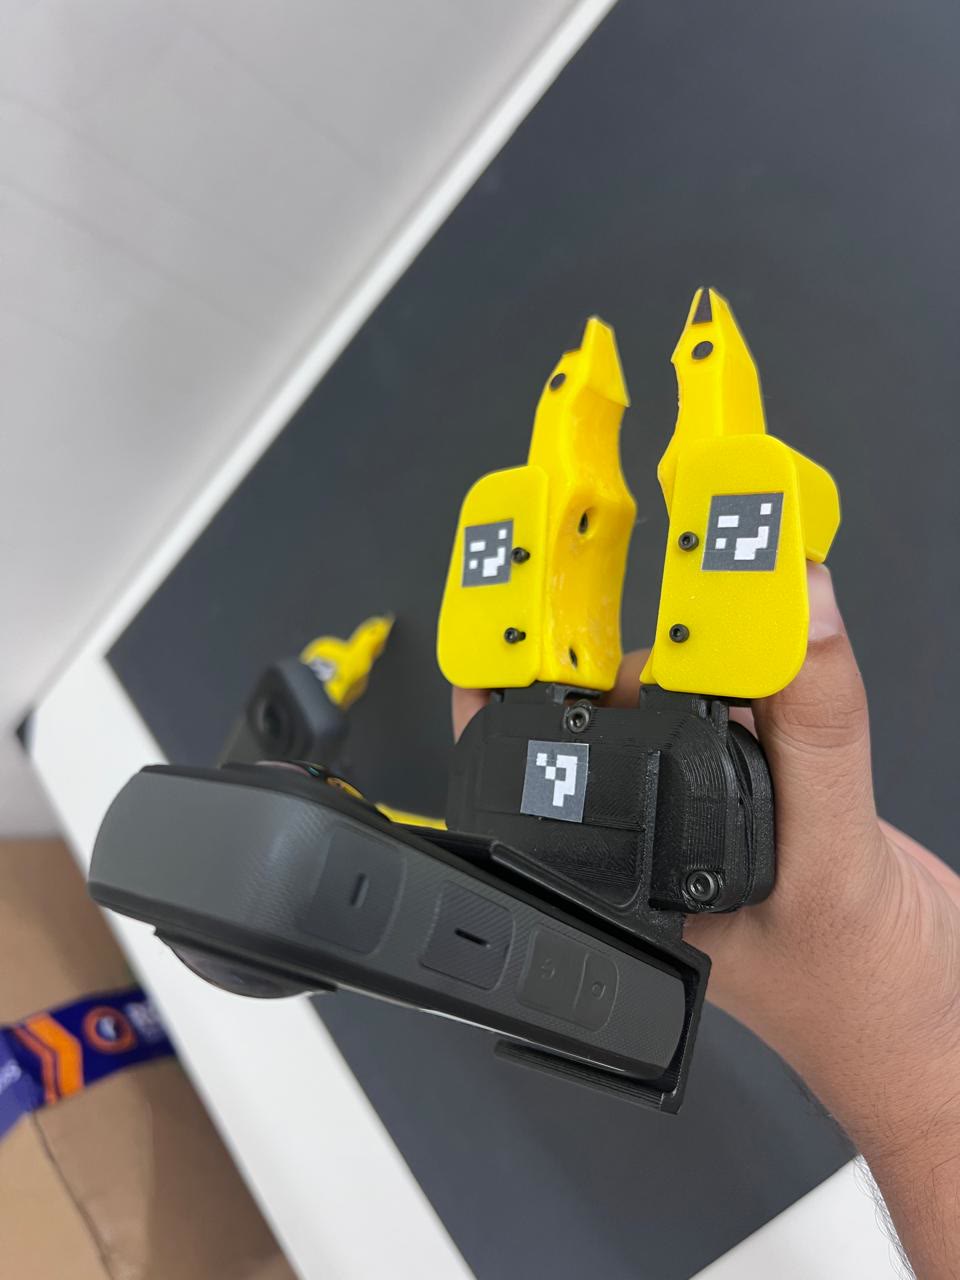
Physical constraints
Operators stay inside the robot's reach.
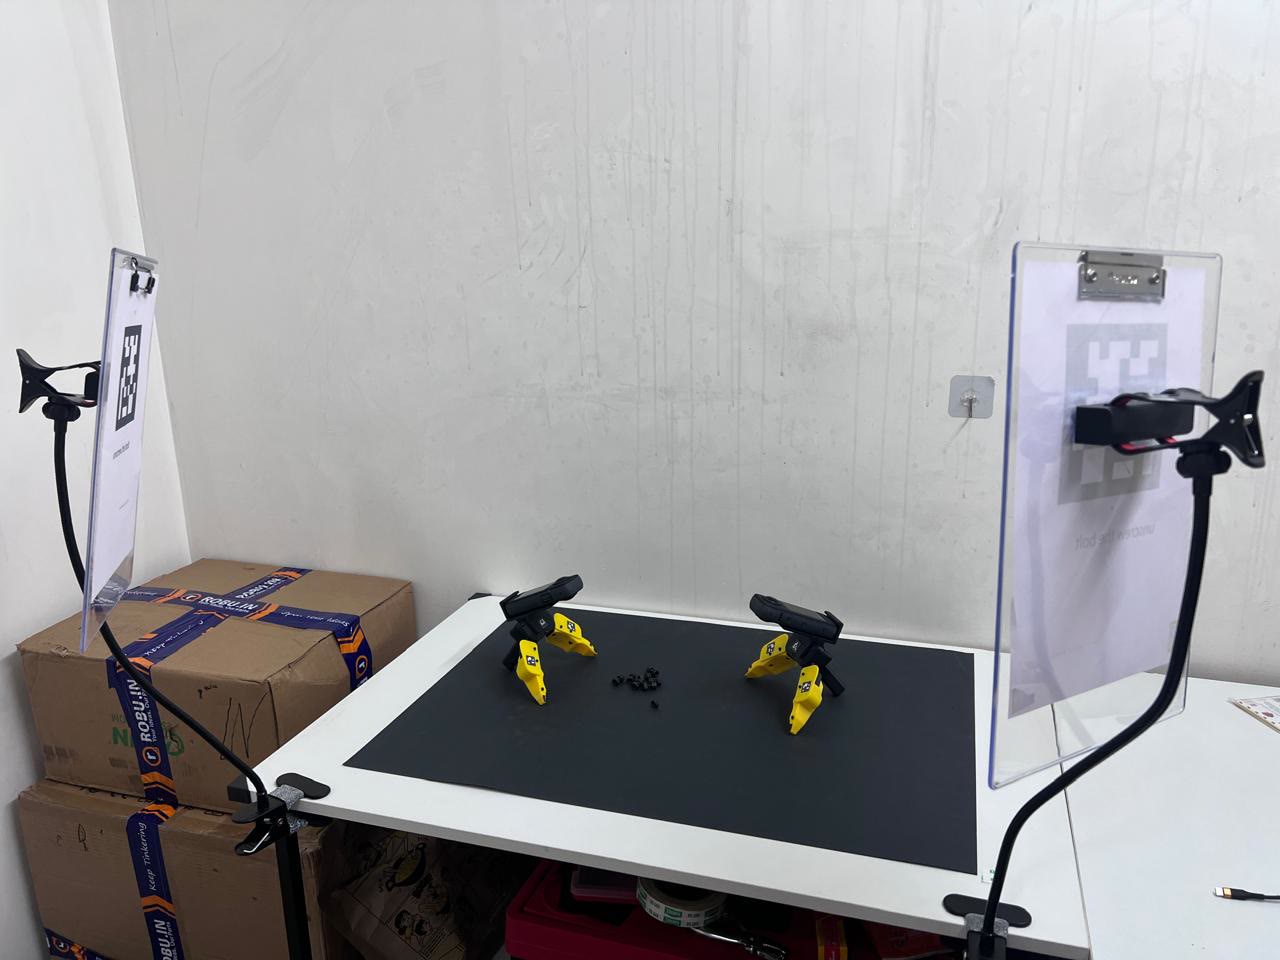
Task card · L
Task card · R
Gripper · left hand
Gripper · right hand
Target objects
Pipeline.
Everything inside the camera frame is maximized for our data annotation needs, continuously reducing post-processing at scale.
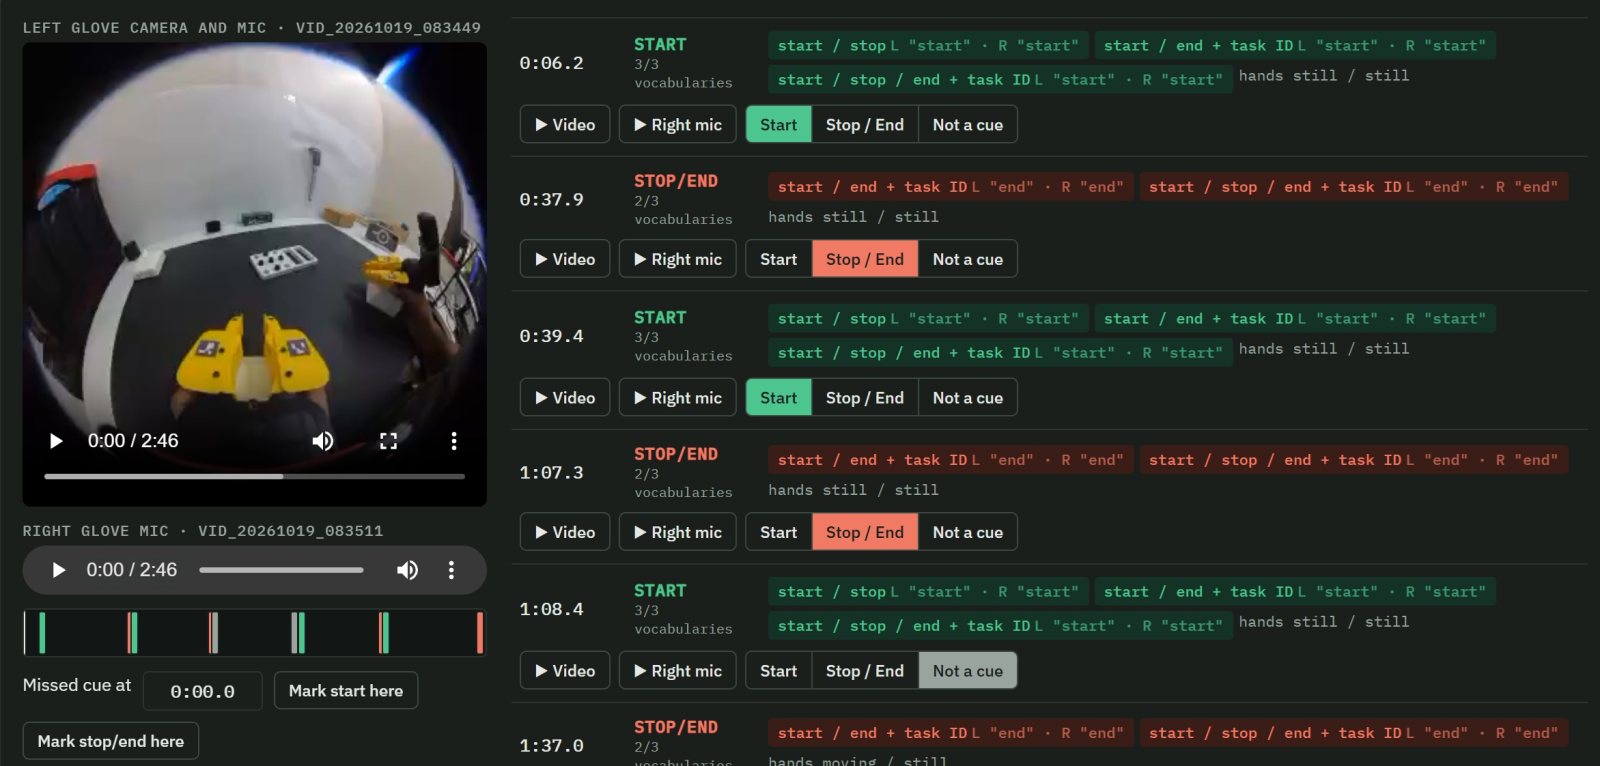
- 01 Wear and record video + rig sensor streams
- 02 Perform the task raw session
- 03 Segment and label labeled episodes
- 04 Track pose + end-effector state
- 05 Retarget target robot joint states
- 06 Verify verified dataset